Software, AI & robotics · Graduating May 2027

Galaba Vamsi

Mechatronics at IIT Bhilai. I build full-stack apps, AI agents, and ML models, and co-founded Human Slop. I also contribute to open-source robotics tools: 15 merged pull requests across HFlow, Inspect Robots, and Cerulion, plus inspect-robots-wandb, a plugin I wrote and publish on PyPI.

Pixel art portrait of Galaba Vamsi

Jack of all trades, master of none (working on it).

Hi, I'm Vamsi. I study Mechatronics at IIT Bhilai, which officially makes me a bit of everything: part mechanical, part electrical, part "can you fix my laptop". I took that personally.

On any given week I'm training a model, shipping a full-stack app, sending a pull request to some robot's software, or arguing with a simulator about physics. Then I close the laptop and go shoot and edit a short film. My browser has too many tabs and I regret none of them.

The full quote goes "jack of all trades, master of none, but oftentimes better than a master of one." I'm betting on the second half. Scroll down for the receipts.

Open-source contributions

Contributor - HFlow

2026

HFlow / Hebbian Robotics (YC S26) / open-source SDK for verifying the quality of robot training data / 8 merged PRs

Most of these PRs make robot-log and LeRobot conversion keep data whole or refuse it with a clear reason.

Contribution log
  • PR #657 · merged · latest · issue #656 — Types Arrow columns from every message, preserving fields introduced after startup and reporting incompatible shapes with topic and field context.
  • PR #598 · merged · issue #597 — Refused sources with multiple channels on one topic before canonical episode creation, added doctor diagnostics, and bumped TRANSFORM_BEHAVIOR_VERSION to 10.
  • PR #400 · merged · issue #399 — Refused LeRobot depth videos before conversion when depth markers were present, preventing the RGB H.264 path from silently losing 12-bit depth semantics while preserving the existing RGB path.
  • PR #367 · merged · featured · issue #365 — Added a reproducible cold camera_frame_stats evidence benchmark: 3 cold 1080p30 checks, 900 decoded frames each, and a 4.897 s median; separated transform timing and provenance, and documented that no repeatable semantics-preserving speedup was demonstrated, so the shipped filter graph stayed unchanged.
  • PR #362 · merged — Matched saved EgoSuite labels by HFlow source provenance instead of basenames, preserving unambiguous legacy reports and rejecting ambiguous matches.
  • PR #360 · merged · issue #314 — Centralized ingest URI parsing across the CLI, server, and SDK with shared trimming and safety checks; normalized safe relative URIs and rejected blank, absolute, and parent-escaping paths.
  • PR #353 · merged · issue #292 — LeRobot video-cache filenames omitted the video file index; included the camera key, video chunk index, and video file index in cache identity and bumped the converter version to invalidate stale outputs.
  • PR #350 · merged · issue #296 — LeRobot’s Hugging Face tree discovery stopped after the first API page; added paginated traversal via Link: rel="next", preserved request headers, deduplicated paths, rejected unsafe cross-origin links, and prevented pagination loops.

Contributor - Inspect Robots

2026

Robocurve (YC S26) builds open-source tools and independent benchmarks for physical AI. Inspect Robots is its MIT-licensed evaluation framework; its CI gates merges on 100% core test coverage, strict mypy, and ruff. / 2 merged PRs / 3 open / author of inspect-robots-wandb on PyPI

Contribution log
  • inspect-robots-wandb v0.1.0 · published on PyPI · source — Weights & Biases logging sink shipped as a standalone package after the maintainers asked for W&B support to live outside the core. Each evaluation becomes one W&B run with the full eval spec as config plus status, trial counts, errored trials, steps, duration, and every aggregate metric. Registers through plugin entry points, 100% coverage, CI on Python 3.10 to 3.13, PyPI trusted publishing.
  • PR #476 · merged · issue #441 — Exposed max_retries and backoff_s on the LLM agent policy across five wire protocols; HTTP retries honor Retry-After (seconds and HTTP-date) with exponential backoff fallback, and the effective settings are recorded in the eval log.
  • PR #475 · merged · issue #473 — Eval logs recorded a bare commit SHA when git status failed, making an unknown working tree look clean; now records unknown provenance, with a regression test.
  • PR #514 · open, in review · issue #136 — Checkpoint and resume for long eval sets on robot hardware: single-writer manifest with input identity checks, immutable per-attempt logs, in-flight markers that block ambiguous replay, retries only for recoverable policy errors (safety aborts and hardware faults stop the run), and atomic writes. New eval-set --checkpoint flag.
  • PR #550 · open — Optional on_eval_error sink hook so sinks holding remote state can clean up when an evaluation aborts; never masks the original exception, notifies each started sink at most once.
  • PR #551 · open — Community plugins section in the plugin guide, listing inspect-robots-wandb.
  • PR #434 · closed by agreement — Original in-repo W&B sink; reviewed as well put together, then split into the external package, #550, and #551.

Contributor - Cerulion

2026

Open-source Rust robot runtime that records a run and re-executes it against new code (iceoryx2 shared memory, ROS 2 interop) / 5 merged PRs: one CLI fix and four documentation and comment corrections

Contribution log
  • PR #216 · merged · issue #53 — cerulion ros2 attach --dry-run no longer needs a throwaway workspace. New engine module resolves the root; an exclusively created temp root (create_dir, bounded retries) means a pre-planted directory can never be read as a schema store, with RAII cleanup on every exit path. Hermetic unit tests, engine integration test, and CLI e2e tests with pinned outcome oracles.
  • PR #226 · merged · issue #71 — Corrected the CERULION_NETWORK kill-switch docs to state the fail-closed arm, verified against source; review surfaced a real gap (topic list never reads the variable), filed by the maintainers as #239.
  • PR #224 · merged — Fixed 21 stale USER_API.md references across 11 files, including runtime error text and its tests.
  • PR #222 · merged — Replaced 26 em dashes in an rmw_cerulion test file's comments so it passes the repo's ASCII-only public-surface check.
  • PR #220 · merged — Corrected misleading CARGO_MANIFEST_DIR comments in cerulion_cli_engine.

Experience

Research Intern - IIT Bhilai

May-Jul 2025

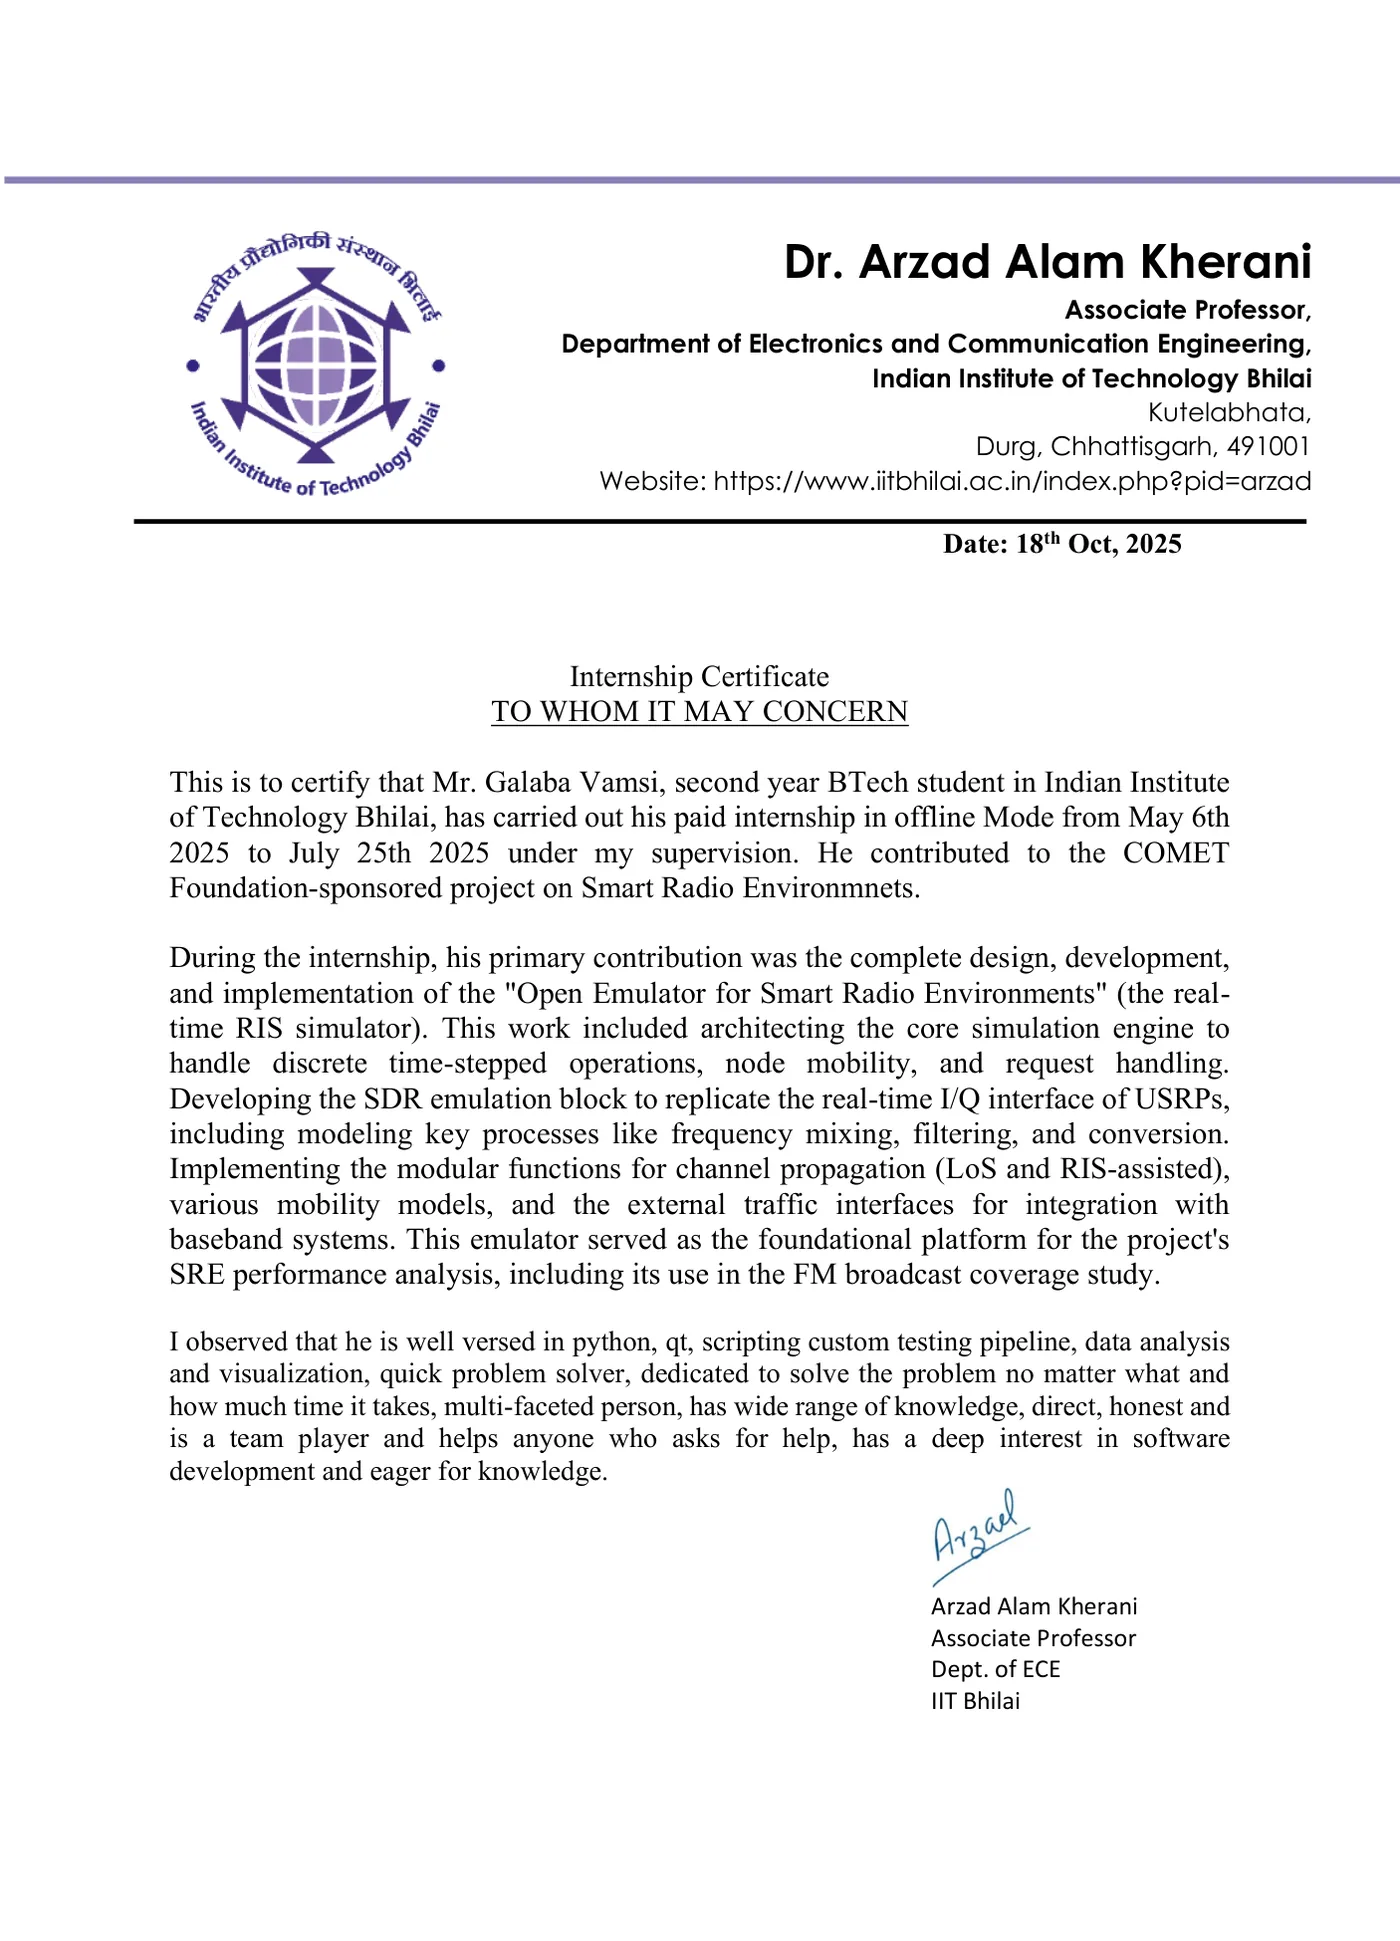
Paid internship / Advisor: Dr. Arzad Alam Kherani / COMET Foundation-sponsored project on Smart Radio Environments

  • Built RIS-SIM, an open-source Python emulator for RIS-assisted radio links in LoS/NLoS scenarios, with USRP-style SDR interfaces so experiments can be prototyped before touching radio hardware.
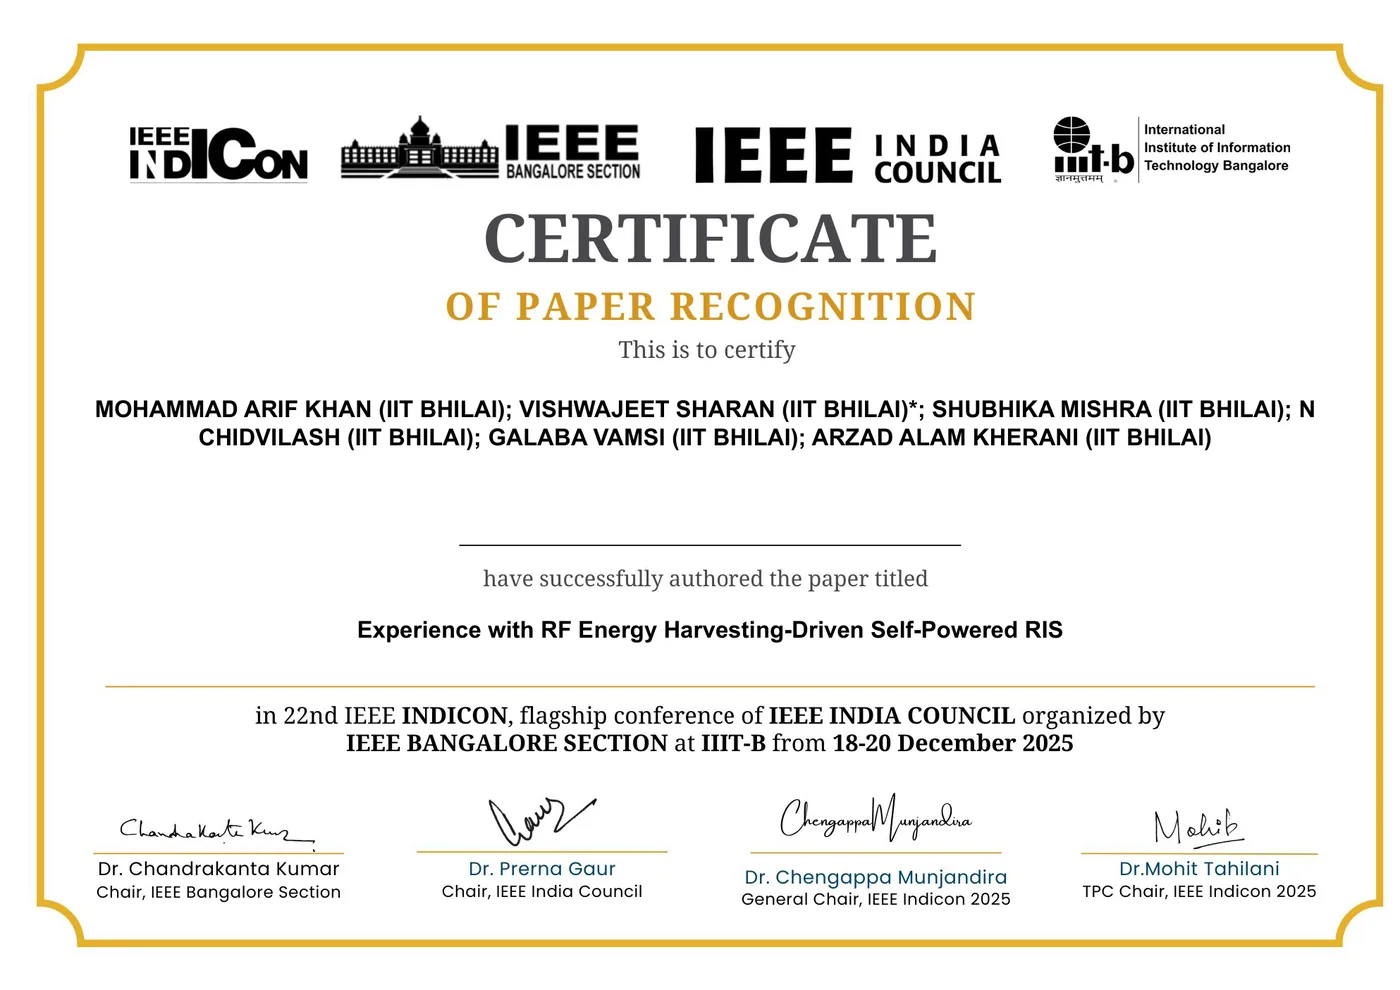
  • Designed RIS unit cells in CST Studio Suite for the lab's RF energy-harvesting work, reported in IEEE INDICON 2025 (co-author).
  • In 2026, rebuilt the emulator as RIS-SIM v2 (six paper-grounded scenarios, a 20 Hz WebSocket dashboard, 103 tests), then from scratch as sremu, a sample-accurate emulator for timed RIS control (see Featured).

Co-founder - Human Slop

2026-Present

Anti-AI social app for human-written posts

  • Co-building it with my co-founder: an Expo (React Native) app for web and Android, a Fastify API, and PostgreSQL on Supabase, deployed on Render and Cloudflare.
  • Live on the web and Google Play (50+ downloads). Attended YC Startup School in Bengaluru.
  • Added a device biometric check at signup (the OS Face ID or fingerprint prompt, tied to a registered device) and a keystroke-timing score in the editor (typing variance, pauses, paste attempts). Both are heuristics, not proof of authorship.

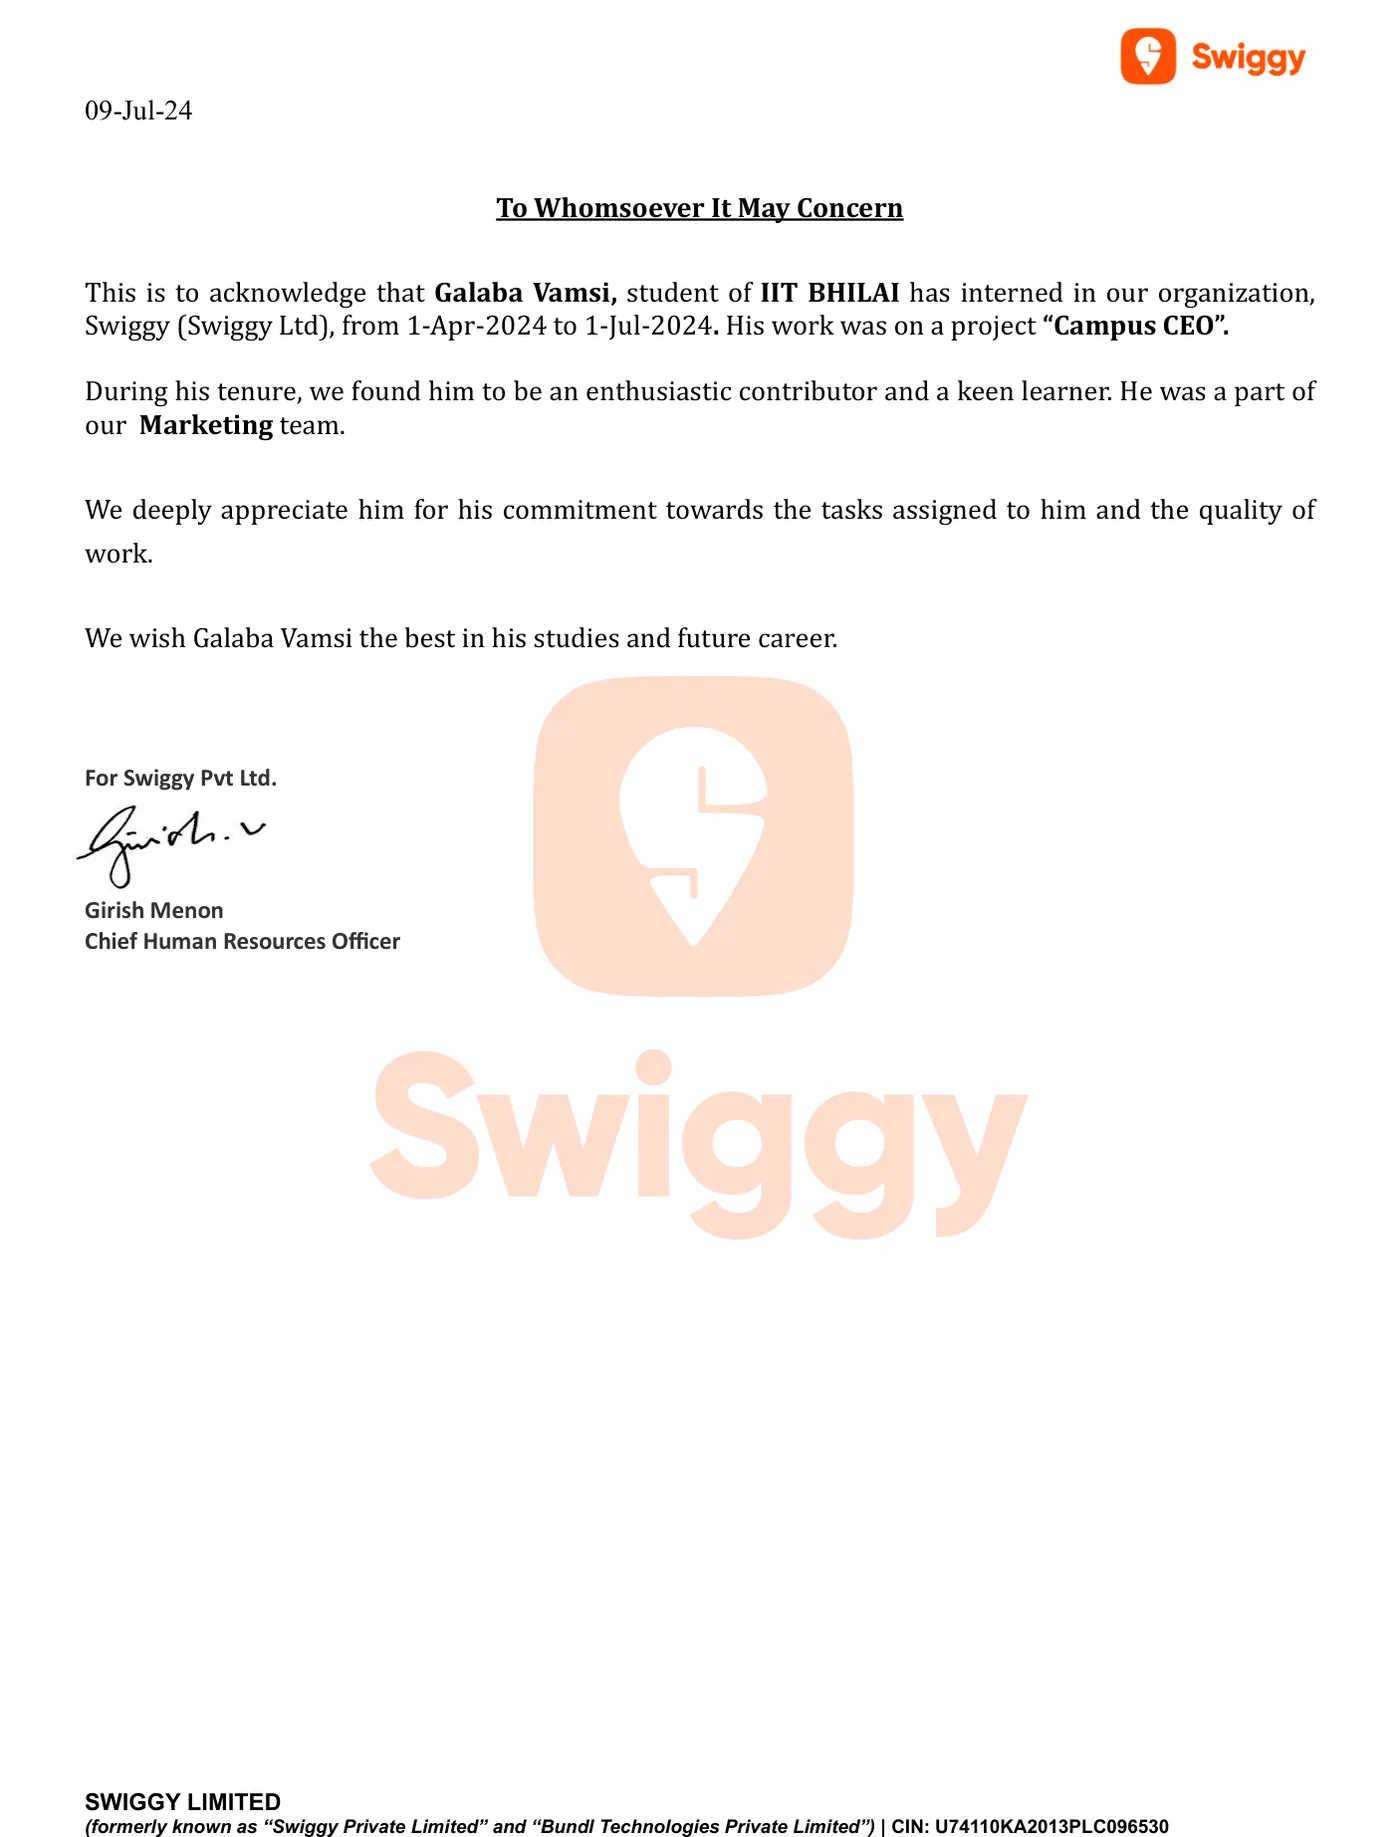
Marketing Intern - Swiggy Campus CEO

Apr-Jul 2024
  • Executed a campus campaign of 15 social media posts.

Projects

Whiteboard Cleaning Robot

Team · 2025

3-DOF Cartesian gantry that cleans a 90 × 90 cm whiteboard, simulated in ROS 2 Jazzy and Gazebo Harmonic: URDF/Xacro model, ros2_control, a raster path with 10 cm overlap, and coverage analysis from logged data. Built with Gajanand Kumawat.

ROS 2 / Gazebo / URDF / Python

Prompt Robot Arm

2026

Kinematic MuJoCo simulation where a prompt such as "sort red, blue, green" is parsed (rule-based for now) into a plan and a pick-and-place sequence, moving from a kinematic gripper to a SCARA arm with analytic inverse kinematics.

MuJoCo / Python / Inverse kinematics

Pneumatic Sorting Digital Twin (offline simulation)

2026

Unity simulation of three electropneumatic training kits (sorting, stamping, vacuum transfer): simulated axes, logical PLC I/O, HMI screens, and telemetry record and replay. Not yet connected to a physical PLC.

Unity / C# / Simulation

Charter

2026

Razorpay AI Buildathon prototype: chat, voice, and MCP (10 tools) share one bounded commerce core with frozen INR quotes, Razorpay test-mode payments, audit trails, and row-level security.

TypeScript / Fastify / PostgreSQL / MCP

WEAR Dataset Challenge @HASCA 2026

Kaggle · 2026

Wearable exercise recognition (18 exercises plus null) from one-second IMU and video tiles of four unseen subjects, scored by macro-F1. 5th of 232 teams on the final private leaderboard (0.93137; 7th on the public one at close, 0.93825). A fork of goodpjw2008’s public notebook, itself built on notebooks by woominyo and honghanhhh. My additions lifted my reproduction from 0.92497 to 0.93825 public: per-subject whitening, whitened video-continuity link features, ZCA video input, and a multi-run ensemble decode. Built in working sessions with Claude.

PyTorch / LightGBM / Kaggle

HeatCast

Team · 2026

Hackathon team project (FortyGuard Hackathon'26, Team HumanSlop): a neighborhood heat-planning scorecard for US planners combining thermal maps, heat-exceedance and streak analysis, vulnerability data, indoor sites, and walking routes.

Next.js / FastAPI / MapLibre / Geospatial

Arista Wi-Fi RRM

Team · 2025

Team project for Arista's problem at Inter IIT Tech Meet 14.0 (5th place, Dec 2025): client-aware Wi-Fi radio resource management in NS-3, with I/Q-based interference classification (STFT, DBSCAN, Dual-CNN; 16 classes) on a 5-AP, 50-client 802.11k/v topology.

NS-3 / STFT / DBSCAN / Dual-CNN

AntennaNet

2026

Inverse antenna design: a surrogate network plus KD-tree nearest-neighbour anchoring over about 2,000 simulated patch-antenna S11 spectra, extended to 12 × 12-pixel (144-dimensional) layouts with a separate method-of-moments dataset, plus MEEP scripts for dataset generation.

Python / PyTorch / MoM / MEEP

Lunar Crater Detection

2026

Crater extraction from lunar DEMs, reproducing Zhou et al. (2018): F1 0.839 on a 16-crater labelled region in Mare Serenitatis (13 true positives, 2 false positives, 3 misses); an optional CuPy path makes preprocessing about 4× faster.

Python / scikit-image / CuPy

AI Village Pond Planning

2026

Terrain-only backend API that turns contour maps into pond-site and catchment recommendations through metric projection, elevation-grid interpolation, D8 flow routing, and GeoJSON outputs.

Python / FastAPI / Geospatial

Open-PyFX

2026

GPU video-effects app in Python, ModernGL, and GLSL: CRT emulation using bundled CRT 3D LUT colour profiles, ASCII edge detection, and 4K export.

Python / ModernGL / GLSL

Electron-GNN

Team · in progress · 2026

In-progress team project (advisor: Dr. Soumajit Pramanik): a two-tower graph neural network (GATv2) that predicts absorption-spectrum peaks from molecular geometry, so far trained and checked on two small molecules (water and ammonia).

PyTorch / GATv2 / GNN

Amazon ML Challenge

Team · 2025–2026

Team entries. AIR 200 in 2026. In 2025, team rank 700 (20,000+ registered participants) with a Qwen2-VL 7B and ViT/RoBERTa two-tower model for product price prediction.

Qwen2-VL / ViT / RoBERTa

Serenity

Team · 2024

Team project: Flutter wellness app with an on-device TFLite mood classifier from the camera, a stress questionnaire, exercises, games, and an expert-contact screen.

Flutter / TFLite / Mobile
Research and publications

Publications

Build logs

One post per experiment: what I set out to test, the exact numbers I measured, and the parts that did not work.

I finished 5th of 232 on a Kaggle wearables challenge.

0.92497 to 0.93825 public, 0.93137 private. What moved the score, a leak that looked like a gain, and why every top team dropped.

Read the write-up ->

I put a decision model in front of my portfolio chatbot.

Keyword rules blocked 12 of 20 real questions; regex let 10 of 12 jailbreaks through. A typed decision model got both to zero on the same 50 labelled messages.

Read the write-up ->

I shipped a Weights & Biases sink for robot evals. Here is how it works.

inspect-robots-wandb v0.1.0 is on PyPI: one W&B run per Inspect Robots evaluation, the full eval spec as config, and every aggregate metric.

Read the write-up ->

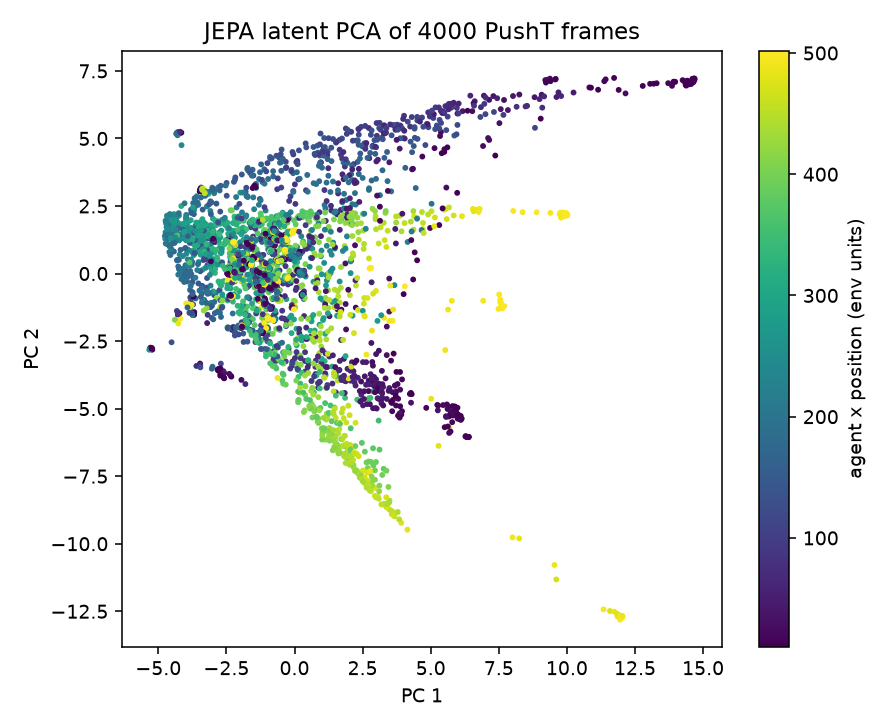
PCA scatter plot of latent embeddings showing a smooth colour gradient by agent x-position.

I trained a world model on my laptop. It learned physics and still could not push a block.

Experiment 01: a 1.9M-parameter JEPA world model on an 8 GB laptop GPU — seven minutes of training, emergent physical state, and a planner that scored exactly zero.

Read the write-up ->

Video essays, films, and builds.

A selection from my YouTube channel, from startup stories and engineering work to short-form filmmaking.

Visit YouTube

Skills

Robotics, simulation, and controls

ROS 2 (rclpy, ros2_control, URDF/Xacro), Gazebo Harmonic, MuJoCo, Unity (C#), MATLAB/Simulink, LQR and Kalman filter design, LeRobot datasets

Languages

Python, TypeScript/JavaScript, C/C++, Rust (open-source contributions), SQL, GLSL

ML, data, and scientific computing

PyTorch, PyTorch Geometric, OpenCV, NumPy, CuPy, Apache Arrow, Weights & Biases, MEEP (FDTD), CST Studio Suite, NS-3, GNU Radio

Software, cloud, and tooling

FastAPI, Node.js (Fastify), React, React Native (Expo), Flutter, PostgreSQL, Supabase, WebSockets, Docker, AWS (CDK, Lambda, Step Functions, Bedrock), Git, Linux, GitHub Actions, pytest, Ruff, mypy, PyPI trusted publishing

Highlights

5th of 232 teams3rd WEAR Dataset Challenge @HASCA 2026 (Kaggle, final private leaderboard, macro-F1 0.93137)
AIR 200Amazon ML Challenge 2026 (team)
5th placeArista Networks Wi-Fi challenge, Inter IIT Tech Meet 14.0 (team, Dec 2025)
AIR 700Amazon ML Challenge 2025 (team; 20,000+ participants)
1st placeIIT Bhilai Web Development Competition
Top 10 finalistToyota Hackathon
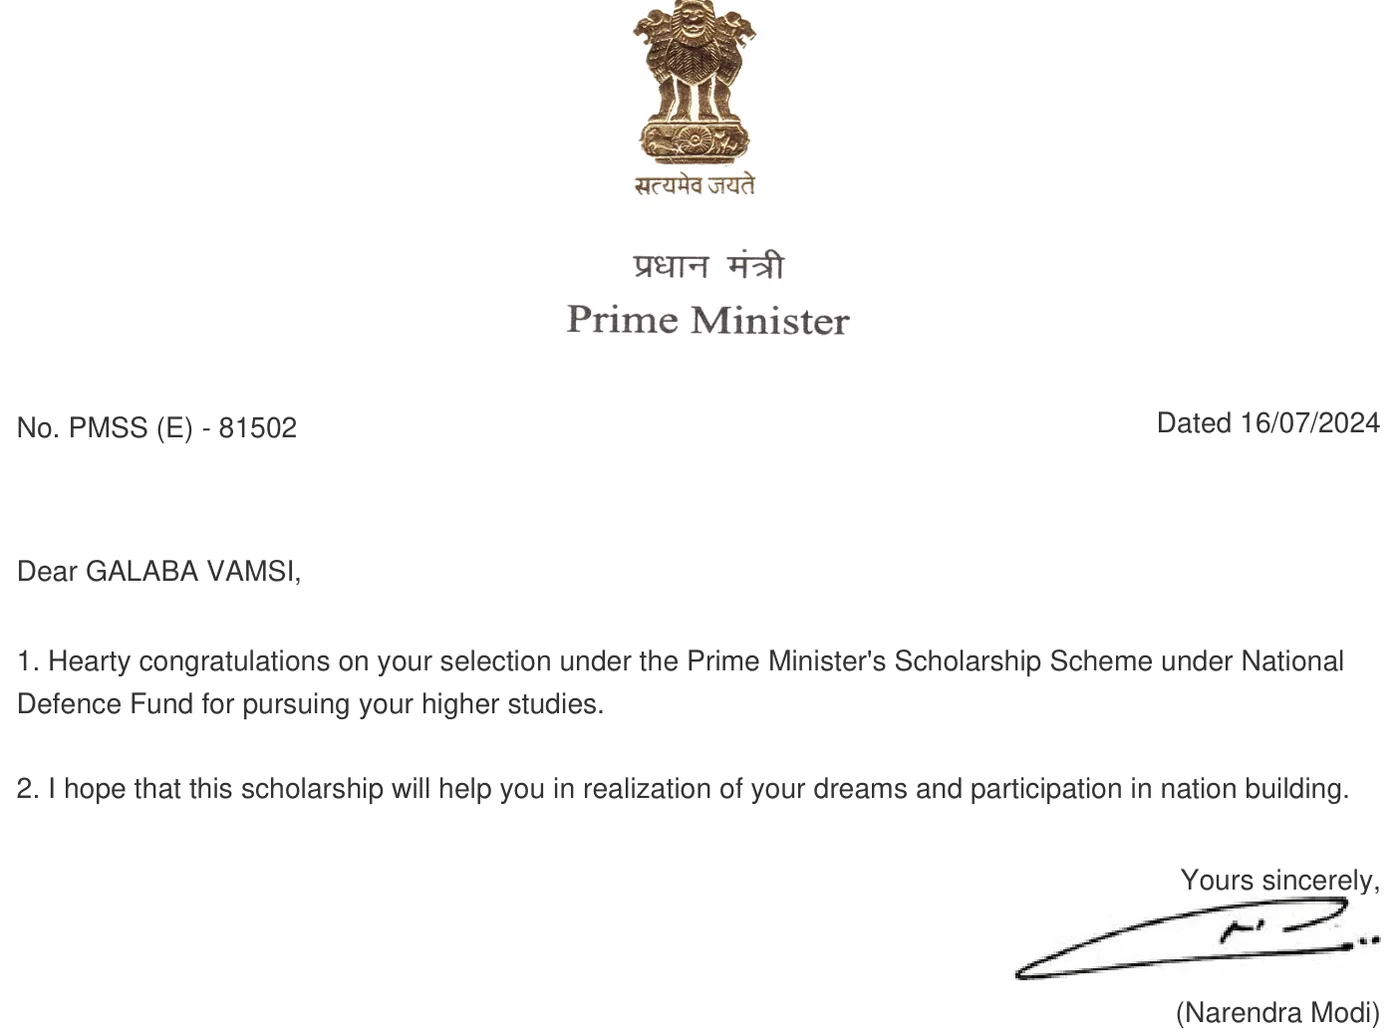
PMSS scholarPrime Minister's Scholarship Scheme, National Defence Fund (2024)
Top 1%JEE Advanced
Academics95% in Class 12, 94% in Class 10

One-page snapshot of my engineering work.

One page: open-source contributions, research, projects, and skills.

Working on robot data, evaluation, or simulation?

Open to robotics software internships and new-grad roles (graduating May 2027), and to research collaborations. I read the code, write the tests, and say plainly what did not work. Email or LinkedIn reaches me.

galabavamsi12@gmail.com / +91 7483047846

Filmmaker / Editor / Director / Writer / IIT Bhilai

Stories with a pulse.

I write, direct, shoot, and edit narrative films, music videos, startup content, and social-first stories where culture, technology, and visual mood meet.

Pixel art portrait of Galaba Vamsi
Idea → script → direction → edit → publish

From music videos to 51-hour films.

Gray Aura official music video thumbnail

Music video / Asita Production

Godchild, Thrsdae — Gray Aura

Directed by Galaba Vamsi and Harshal Singh. Cinematography by Harshal Singh, Galaba Vamsi, and Aditya Singh. Edited by Galaba Vamsi.

God Inter-IIT 8.0 film thumbnail

FPS / Inter-IIT 8.0

FPS — 51-hour filmmaking

Director, editor, and writer with FPS — IIT Bhilai, developing, shooting, and finishing films under extreme time constraints with a student production team.

Launching Human Slop video thumbnail

Startup / Product storytelling

Human Slop

Created and contributed to launch and social content for the anti-AI social platform I co-founded, translating a technical product into visual stories for an internet-native audience.

Shorts, experiments, and campus work.

I can take a project from first idea to final publish.

01 / StoryIdea, script, structure, and visual references.
02 / ProductionShot planning, direction, camera, actors, and crew.
03 / PostEditing, sound, visual polish, and fast-turnaround finishing.
04 / ReleaseSocial-first cuts, product storytelling, and final publishing.

My technical background in robotics, simulation, computer vision, and software gives me an extra edge with cameras, digital tools, visual effects, interactive media, and technical products.